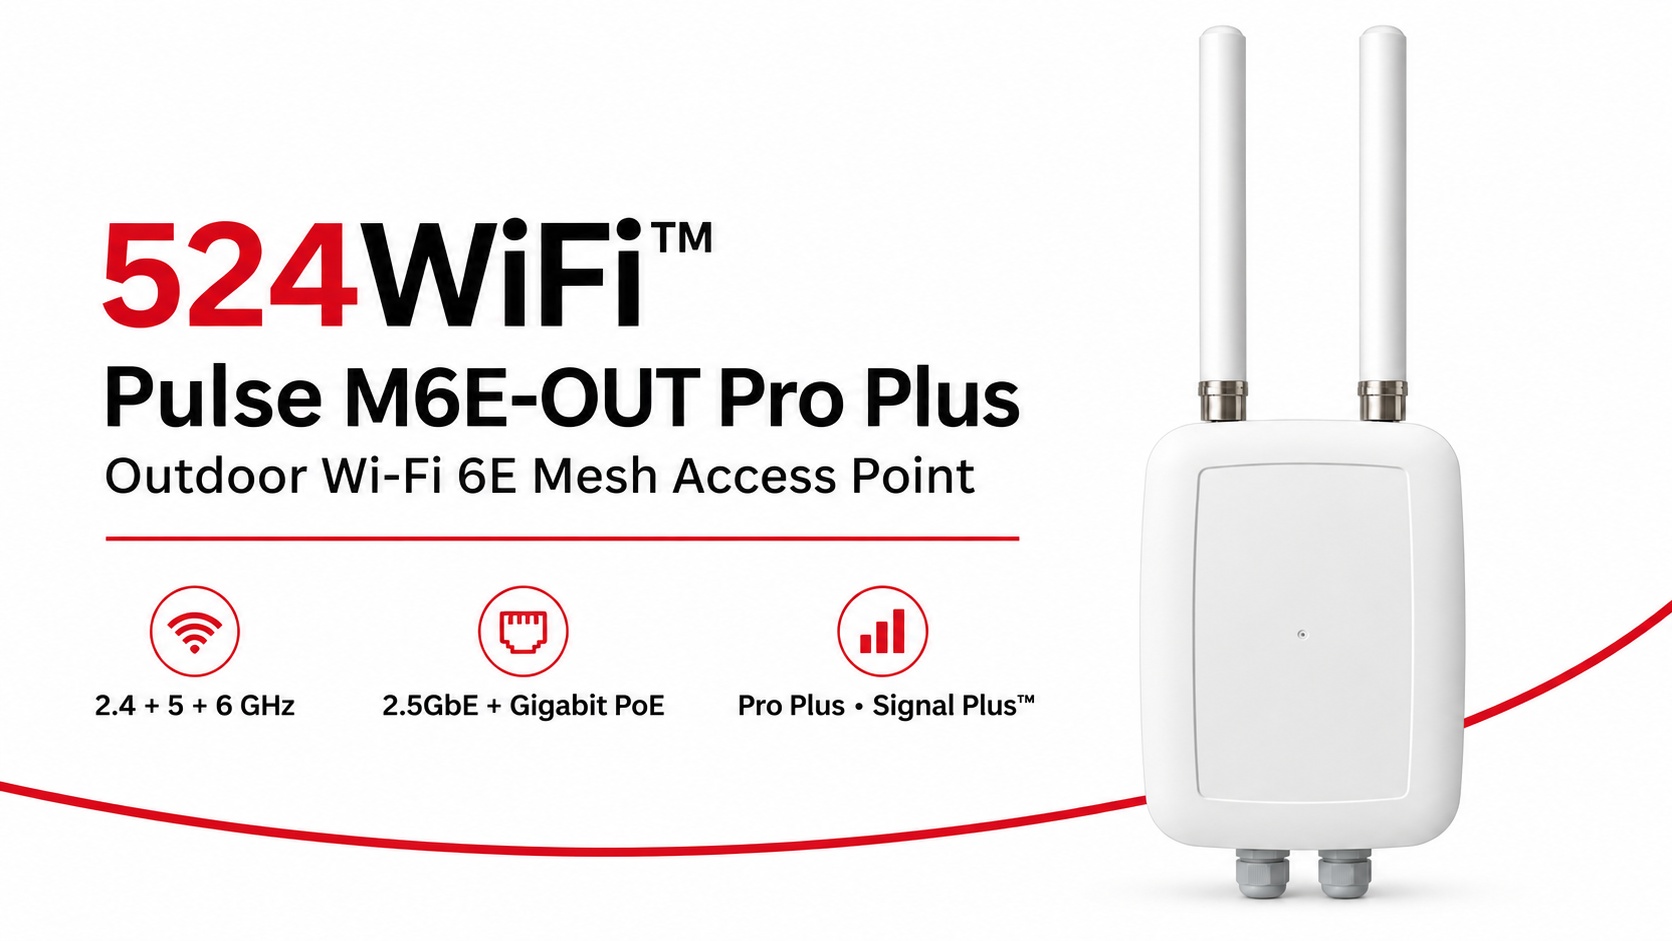
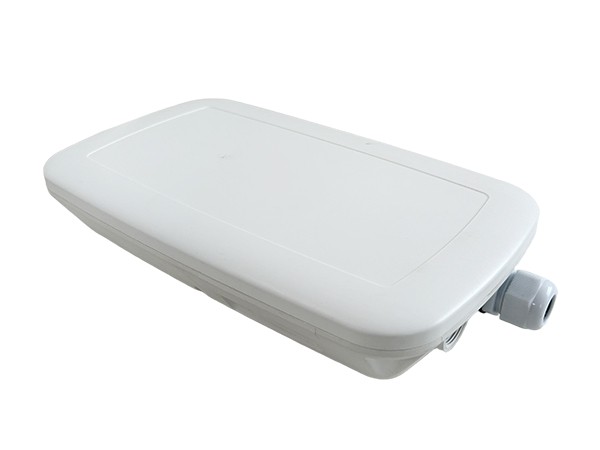
524WiFi™ Pulse M6E-OUT Pro Plus brings the radio platform, outdoor enclosure and model-specific antenna assembly together for a professionally planned Wi-Fi 6E mesh installation. Start with a complete fixed network node and build coverage and inter-node links around the working area.
Three radio bands for the complete site network
Independent 2.4, 5 and 6 GHz radios give the installation three concurrent 2×2 radio paths. The Qualcomm IPQ5018 platform combines a dual-core ARM Cortex-A53 processor at 1.0 GHz with 512 MB DDR3L. A 2.5GbE interface supports the wired uplink, while a Gigabit Ethernet interface with PoE provides practical network and power integration.
The published theoretical PHY rates are up to 573 Mb/s at 2.4 GHz and 2,402 Mb/s each at 5 and 6 GHz. Channel widths reach 40 MHz at 2.4 GHz and 160 MHz on the two higher bands. Choose channels and radio roles around client traffic, the mesh topology and the operating country.
An antenna assembly matched to the outdoor node
The assembly combines two external 5 GHz omnidirectional antennas, two internal 2.4 GHz omnidirectional antennas and an internal directional 6 GHz panel serving the two 6 GHz RF paths. Aim the panel toward the intended link and keep its enclosure face clear of metalwork. This lets the installation use directional interconnection and local coverage deliberately.
Pro Plus and Signal Plus™ for deployment
Pro Plus combines our tuned product configuration, model-specific firmware selection and integration support. Signal Plus™ brings antenna placement, polarization, feed losses, radio roles and channel planning into the same RF system. Commission the complete node under the traffic and RF conditions of the actual site.
Fixed mesh nodes and moving clients
Use the M6E-OUT as a fixed outdoor infrastructure node. Pair it with Pulse M6E-IN for indoor infrastructure and Pulse R6-D2-IN or R6-T3-IN roaming clients on moving Ethernet-equipped machinery. Plan compatible firmware, authentication and RF overlap across the route. Mesh interconnection and moving-client roaming serve complementary roles in the complete network.
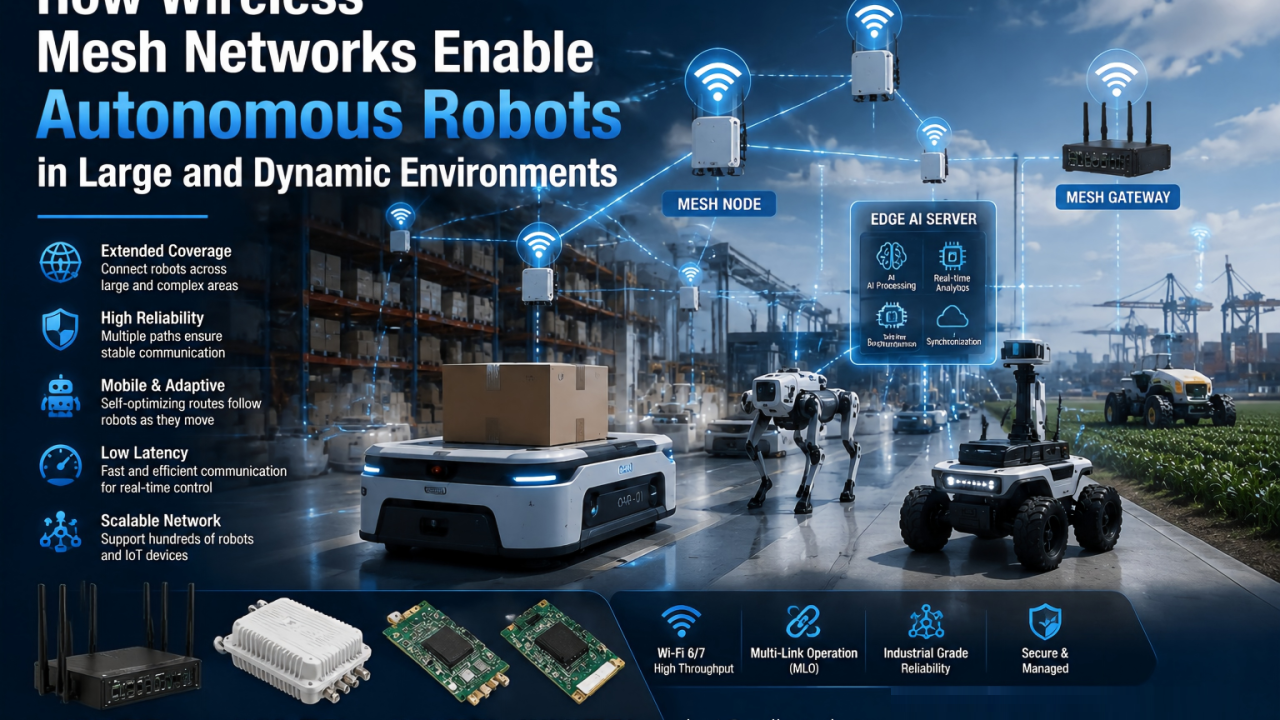
Mobile robots used to be limited mainly by batteries and mechanics. Increasingly, the limit is data movement. A modern AMR or UGV carries multiple cameras, LiDAR, and depth sensors. It runs perception models on board, and it has to stay connected while roaming across a warehouse, port, or factory floor. Compute has advanced quickly with NVIDIA Jetson. The wireless link has often stayed one generation behind.
Pairing Jetson-class edge compute with a Wi-Fi 7 network is one practical way to close that gap.
Why Jetson and Wi-Fi 7 belong in the same architecture
Jetson runs perception, localization, and navigation on the robot itself, so the robot does not depend on the network for real-time decisions. But the network still carries the data that matters at fleet level:
Compressed multi-camera streams for remote monitoring and teleoperation
Map and model updates pushed to many robots at once
Fleet telemetry, task dispatch, and OTA firmware
Handover of the robot’s connection between access points while moving
Wi-Fi 7 (IEEE 802.11be) addresses these directly. Channels of up to 320 MHz in the 6 GHz band raise per-link capacity. 4K-QAM raises spectral efficiency. Multi-Link Operation (MLO) lets a client use more than one band to improve reliability and reduce latency variation. Multi-RU scheduling helps when many small clients share a channel, which is the typical multi-robot case.
How the pieces fit together: 524WiFi™ edge platform
At 524WiFi™, we treat the robot’s compute and its radio as one design problem rather than two separate purchases.
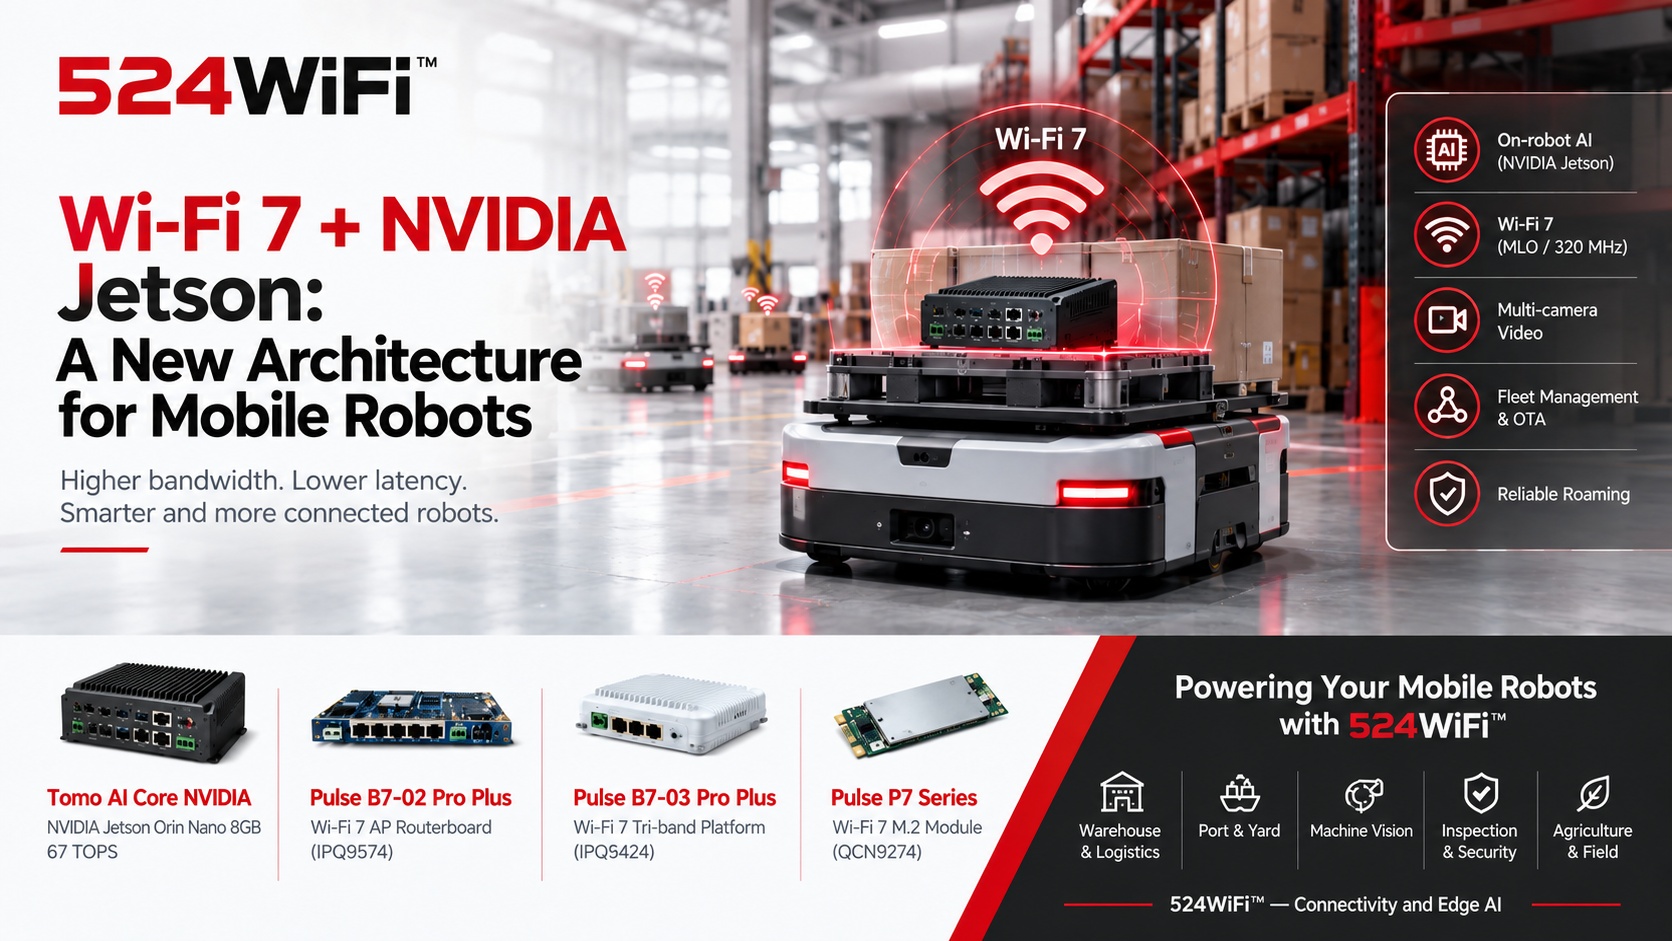
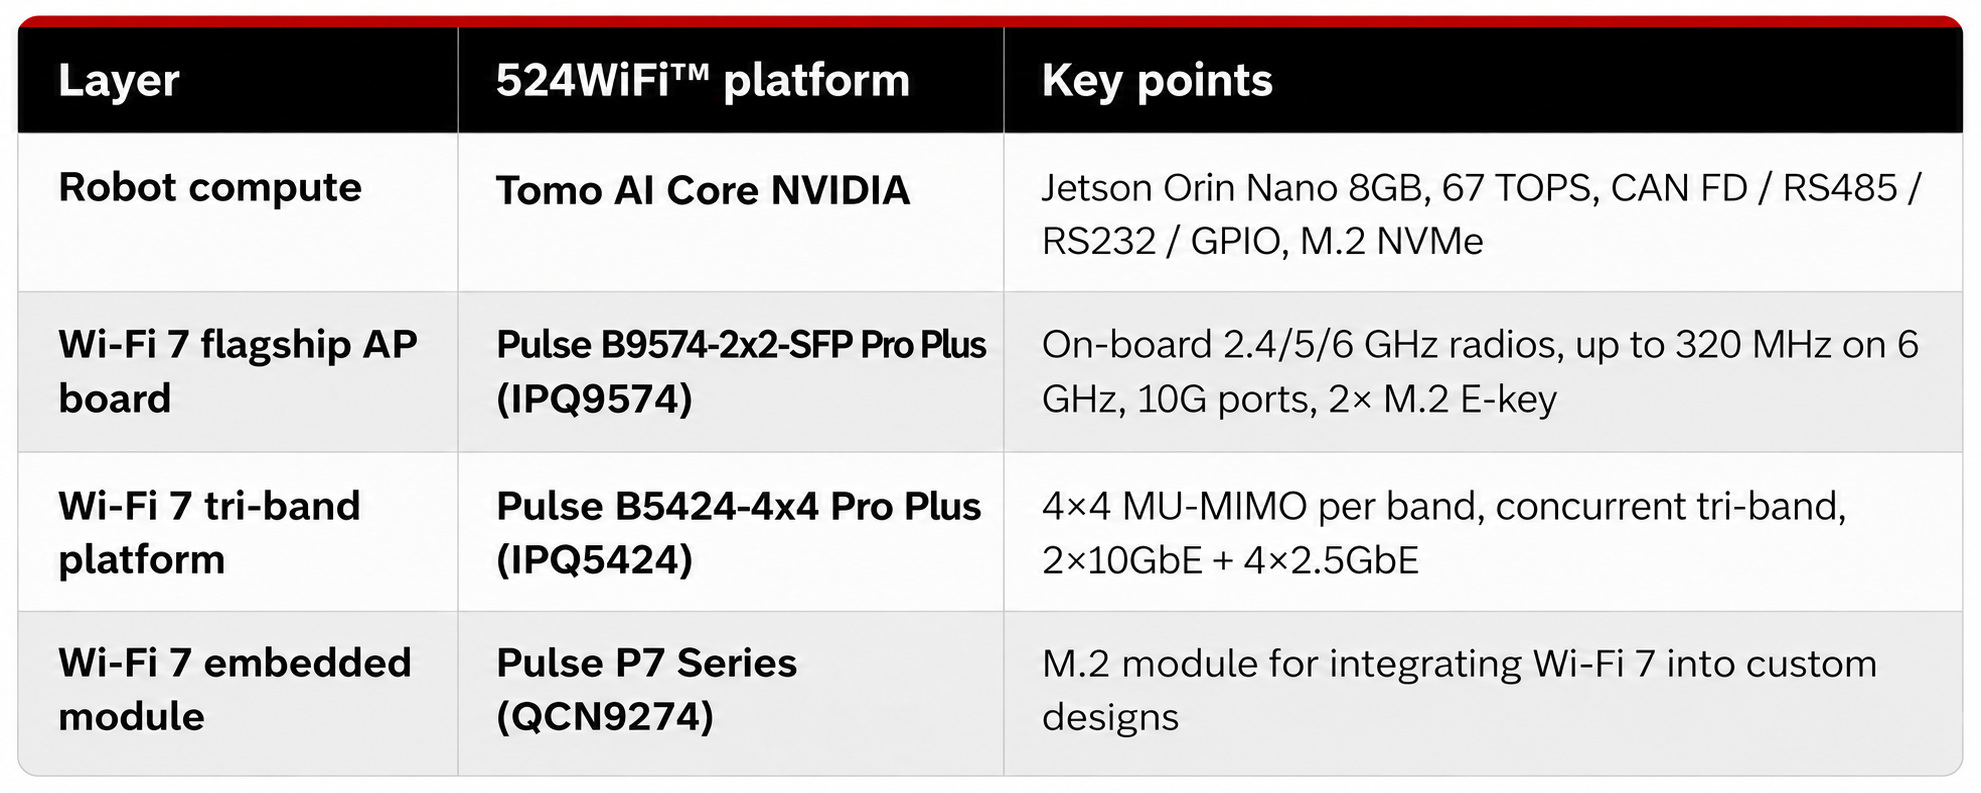
On the robot: the Tomo AI Core NVIDIA is built on the NVIDIA Jetson Orin Nano 8GB module with an industrial carrier board. It offers 67 TOPS of AI performance. Connectivity includes Gigabit Ethernet (one port with 48V PoE), optional Wi-Fi, and optional 4G/5G. Robot-side I/O includes CAN FD, RS485, RS232, GPIO, USB 3.0, and an M.2 NVMe slot. Select the compute, carrier I/O and wireless configuration around the requirements of the robot application.
On the infrastructure side: Wi-Fi 7 platforms based on Qualcomm silicon serve as the access point layer. Examples are the Pulse B9574-2×2-SFP Pro Plus (IPQ9574), the Pulse B5424-4×4 Pro Plus (IPQ5424), and the Pulse P7 Series M.2 modules (QCN9274) for embedding Wi-Fi 7 into your own hardware.
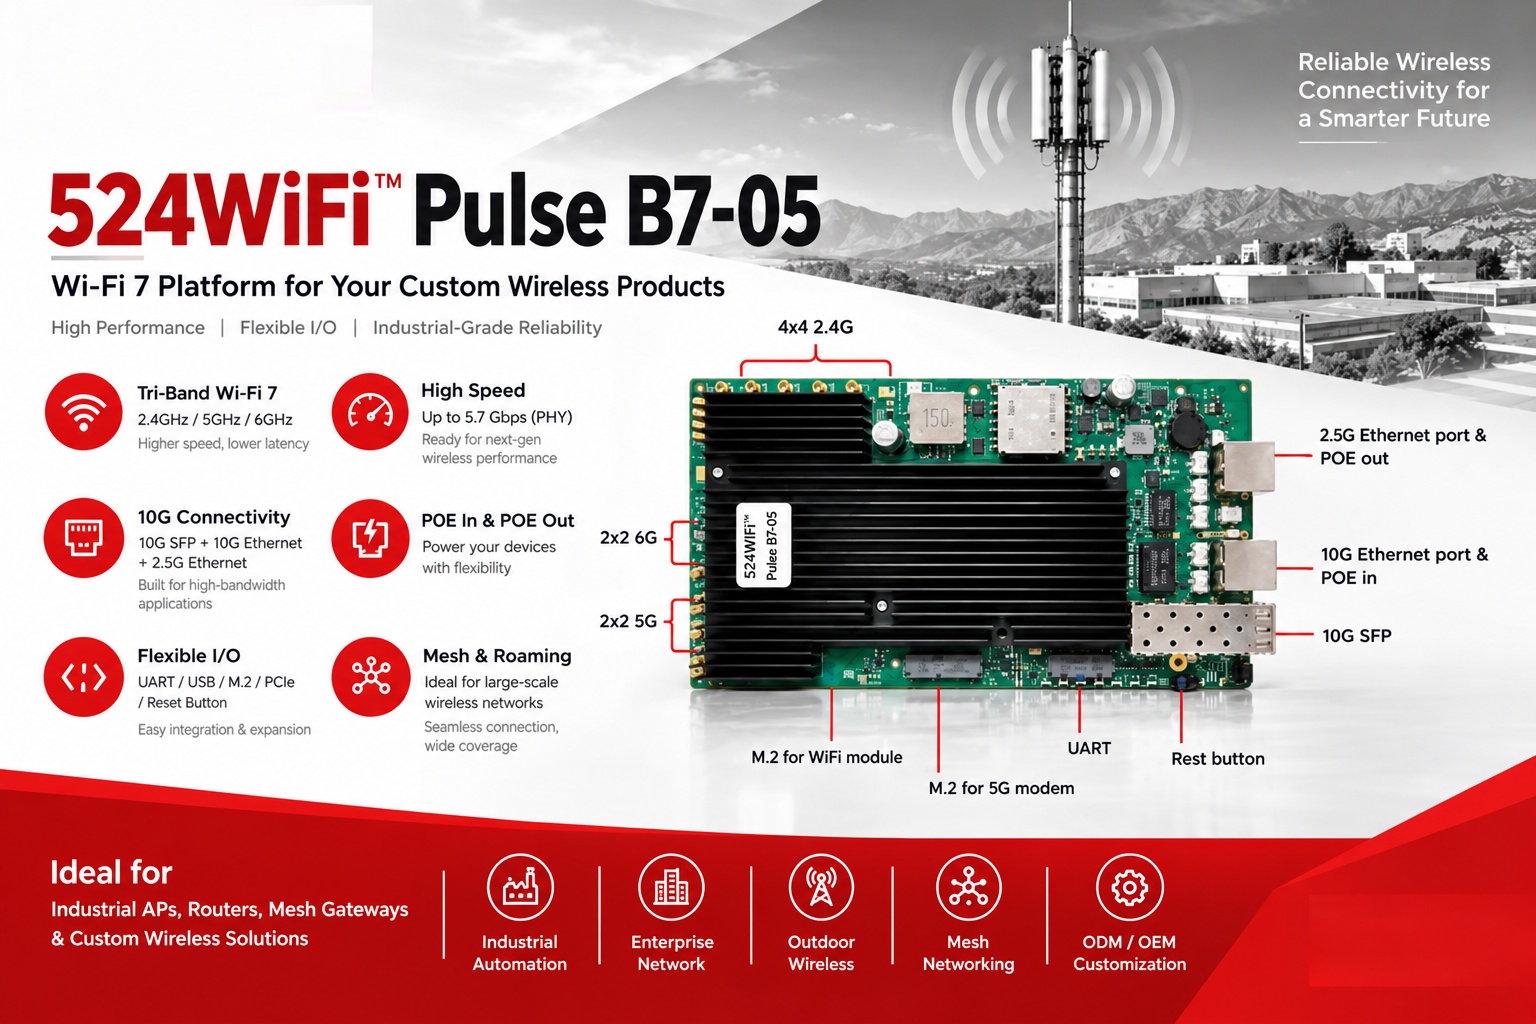
One point worth stating clearly: tri-band does not always mean the same thing. On the Pulse B5424-4×4 Pro Plus and Pulse B9574-2×2-SFP Pro Plus, the 2.4 GHz, 5 GHz, and 6 GHz radios are three independent chains running concurrently. Some tri-band cards are tri-band switchable, meaning one radio moves between bands to avoid interference. Both approaches are useful, but they suit different designs, so check which one a product actually is before planning around it.
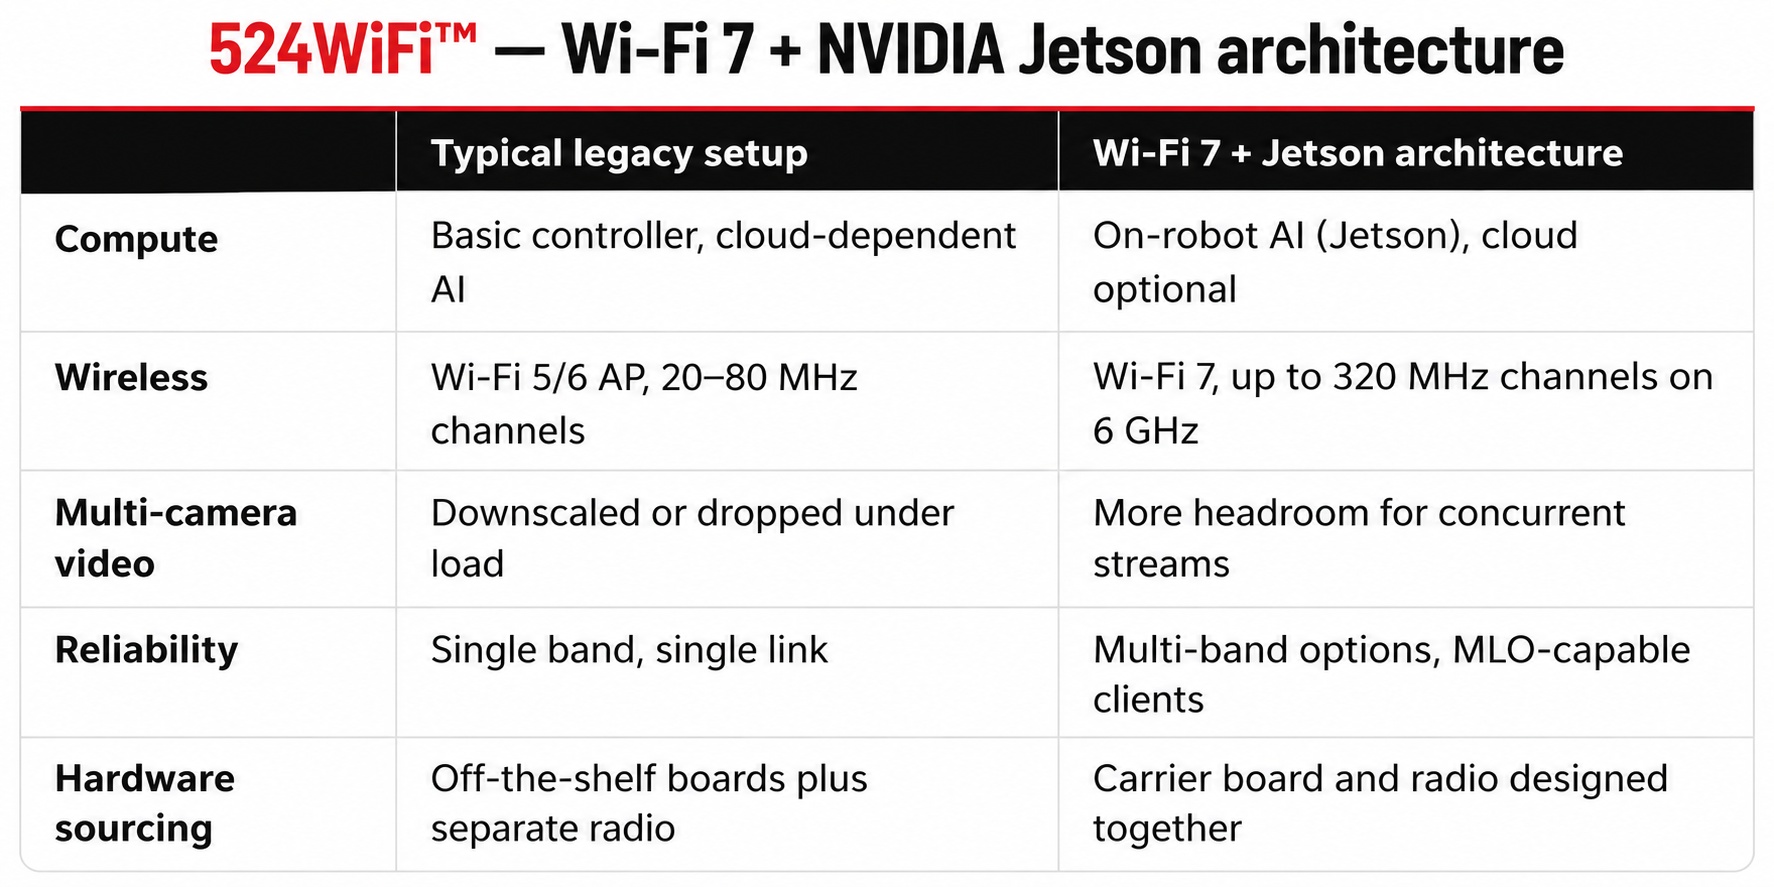
Compared with the usual approach
Wi-Fi 7 is not a magic fix. Real roaming performance still depends on AP placement, channel planning, and client support. But the higher-capacity link and the multi-band tools give the network more room to work with.
Where this architecture applies
Warehouse and logistics AMRs: dense multi-robot fleets with steady roaming and continuous telemetry
Port and yard vehicles: long-range coverage with camera-based monitoring
Machine vision on the move: multi-camera, high-resolution image transfer to inspection systems
Inspection and security robots: live video plus on-board detection
Agricultural and field robotics: long-range control and video links, with custom transmission software where needed
Hardware summary
Talk to us
If you are building mobile robots on Jetson and would rather not develop the wireless hardware yourself, we can supply the modules, routerboards, and custom carrier boards, and discuss the application software and transmission requirements of the complete system.
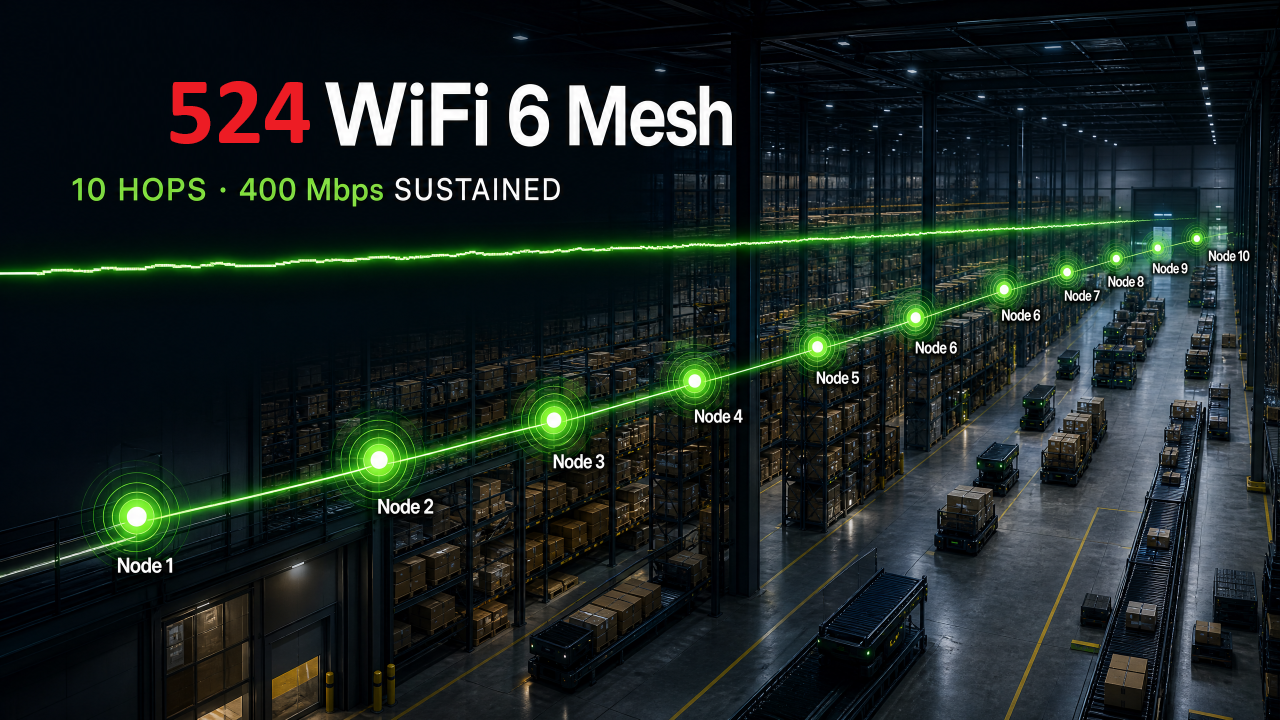
Most industrial mesh networks start choking after 3-4 hops — latency spikes, throughput collapses, and your robots lose their control link exactly when you need it most.
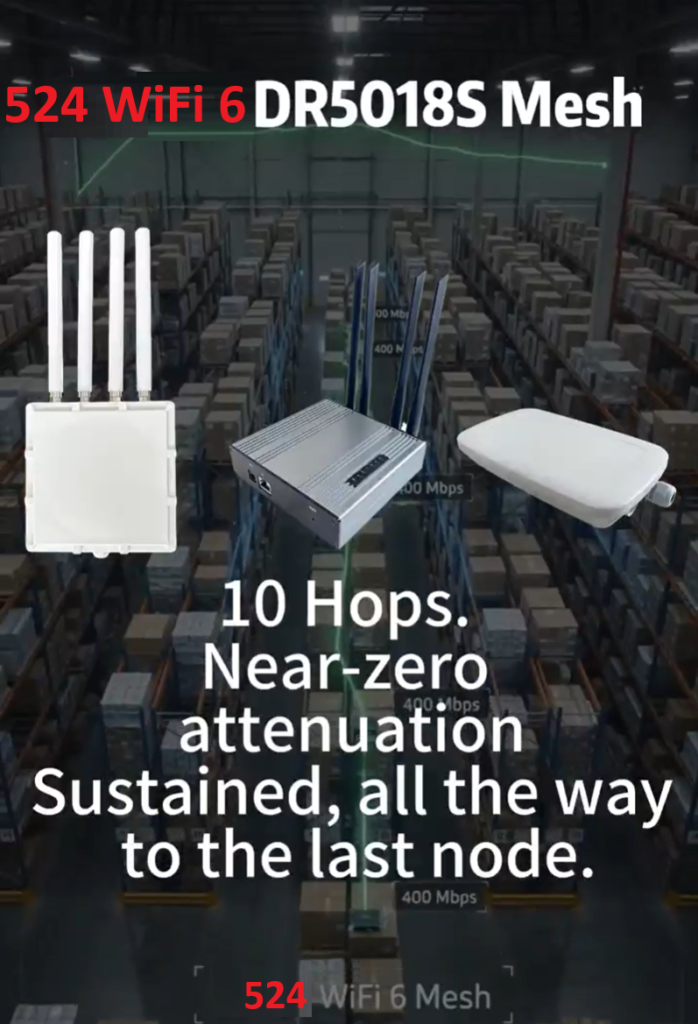
We just wrapped a 10-hop mesh stress test on our WiFi 6 platform, and the results speak for themselves: near-zero attenuation across all 10 hops, with sustained throughput of 400Mbps at the final node.
524WiFI mesh 10 hops testing environment
For AMR fleets, warehouse automation, and multi-robot deployments, this isn’t a lab number — it’s the difference between a robot that stays connected across a 50,000 sq ft facility and one that drops out the moment it turns a corner.
From PC1 to PC2 10 HOPS THROUGHPUT TEST RESULTS
No more compromising on coverage. No more babysitting mesh hops. Just reliable, high-throughput connectivity that scales with your facility, not against it — no need for WiFi 7 to get there.
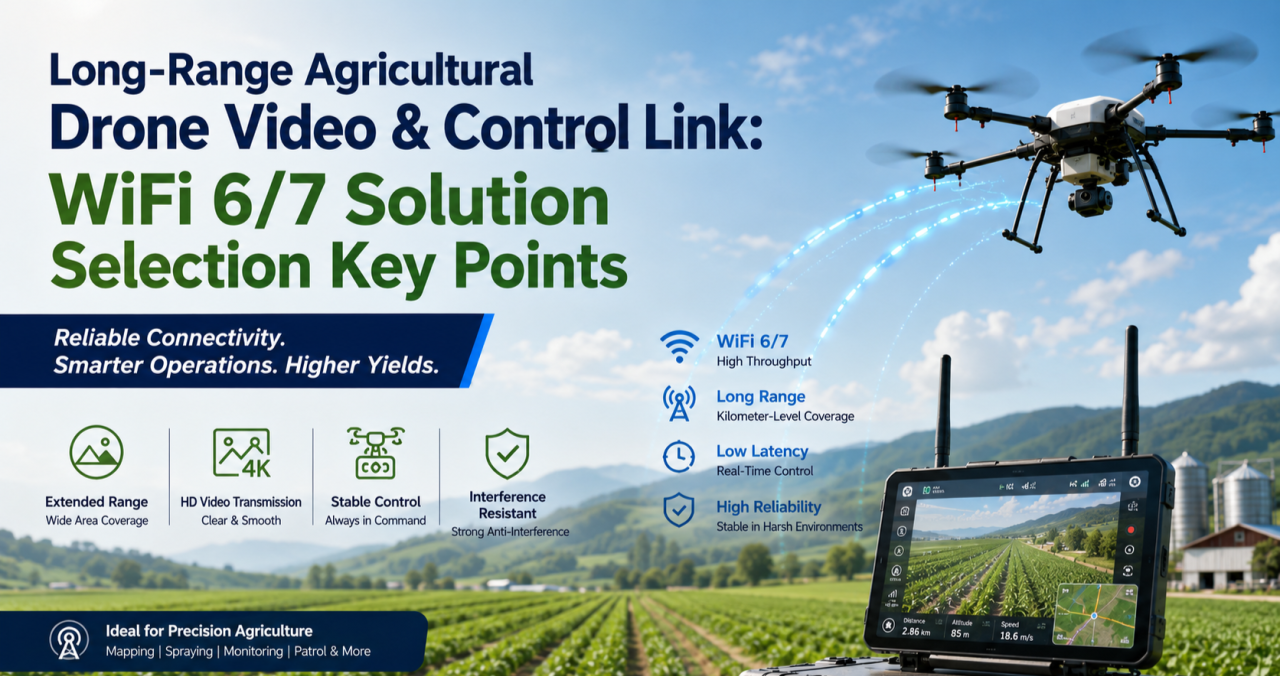
If you’ve deployed drones for crop spraying, field mapping, or orchard inspection over any real distance, you’ve probably run into this: the link holds fine at 200 meters, then starts dropping commands or breaking up video well before you hit the range the datasheet promised. It’s rarely a bad chip. It’s almost always an architecture problem.
This guide walks through why long-range agricultural links behave differently from indoor or short-range WiFi deployments, what actually determines reliability at range, and how to select hardware — control-side and video-side — that holds up in the field.
Why Agricultural Drone Links Are a Different Problem
Most WiFi hardware is designed and benchmarked for indoor, short-range, high-density environments — offices, warehouses, retail. Agricultural drone deployments invert almost every one of those assumptions:
Distance is the default, not the exception. A single control link routinely needs to cover several hundred meters to a few kilometers across open farmland or orchards.
There’s no multipath to lean on. Indoor WiFi benefits from reflections off walls and ceilings. Open fields don’t offer that — and offer very little shielding from other interference either.
Control and video have opposite requirements. Control commands are small, frequent packets that need low, consistent latency and near-zero loss. Video (especially 4K, multispectral, or thermal payloads) needs sustained bandwidth and can tolerate some jitter. Serving both well on one link is hard.
One-to-many is common. A single ground station frequently needs to manage multiple aircraft flying formation or covering different zones of the same field, which means the AP side has to handle concurrent, fast-moving clients — not a single static link.
Power is capped by regulation, not by ambition. ISM-band transmit power and antenna gain both have legal ceilings. You can’t out-power your way to more range.
The Five Things That Actually Determine Reliability at Range
1. Band Strategy: Split the Link, Don’t Pick One Band
2.4GHz diffracts better around terrain, crops, and structures, which is why it’s traditionally the default choice for long-range control links. 5GHz and 6GHz offer far more spectrum and fewer competing signals, which is exactly what high-resolution video needs.
The reliable pattern in the field isn’t choosing one band for everything — it’s running a split architecture: control on 2.4GHz, video on 5GHz or 6GHz. That’s a strong argument for radio hardware where the band configuration is flexible (single-band, dual-band, or switchable tri-band) rather than fixed to one band at the factory.
2. Modulation and Spatial Streams: Know What They Actually Control
Specs like 4096-QAM and multi-stream MU-MIMO are real and useful — but they define your near-field ceiling, not your far-field floor. As distance increases and signal-to-noise ratio drops, the link automatically falls back to lower-order modulation regardless of the chip’s peak capability.
When evaluating hardware for a long-range deployment, the number that matters isn’t the “Gbps peak” on the datasheet. It’s the rate-adaptation curve under low SNR, and specifically the minimum usable data rate at the outer edge of your intended range. That’s the number that tells you whether video will break up or commands will get dropped when the aircraft is farthest from the ground station — which is exactly when you need the link most.
3. MLO (Multi-Link Operation): Redundancy, Not Traffic Splitting
WiFi 7 introduced Multi-Link Operation, which lets a device establish links across multiple bands or channels at once. There’s a common misconception worth clearing up here: MLO isn’t a way to route control traffic on one band, video on another, and backhaul on a third, each running independently.
What MLO actually does is transmit the same data redundantly across multiple links simultaneously, so that if one link momentarily fades or gets interfered with, the other link covers for it — improving reliability and reducing effective latency. For agricultural drones, where a lost link is often the trigger for a return-to-home failsafe, that kind of redundancy has real operational value, not just a spec-sheet checkbox.
4. Topology: Point-to-Point vs. One-to-Many
A single aircraft doing long-range mapping or inspection is often best served by a point-to-point link — a directional antenna setup trading beamwidth for range and stability. But if a ground station needs to manage multiple aircraft or ground terminals simultaneously, the AP side needs OFDMA multi-user scheduling and fast roaming/handoff behavior, or you’ll see queuing delay whenever multiple aircraft check in around the same time.
Know which problem you’re actually solving before you pick hardware — they call for different radio capabilities.
5. Form Factor: Airborne and Ground-Side Needs Diverge
The airborne side is constrained by payload weight and available power, so it needs a small, low-power radio module that can be integrated directly into a flight controller or gimbal payload — with just enough band flexibility to serve the control link without unnecessary weight or draw.
The ground station side is a different design problem entirely: it needs to aggregate multiple client connections, handle higher sustained throughput, and typically needs wired backhaul (Ethernet, sometimes 10GbE) to move the collected video and telemetry off to a local server or the cloud. That usually points toward a board-level platform rather than a compact module.
Mapping Hardware to the Problem
Once you’ve worked through the five factors above, hardware selection becomes a matter of matching platform to role rather than chasing a single “best” spec sheet.
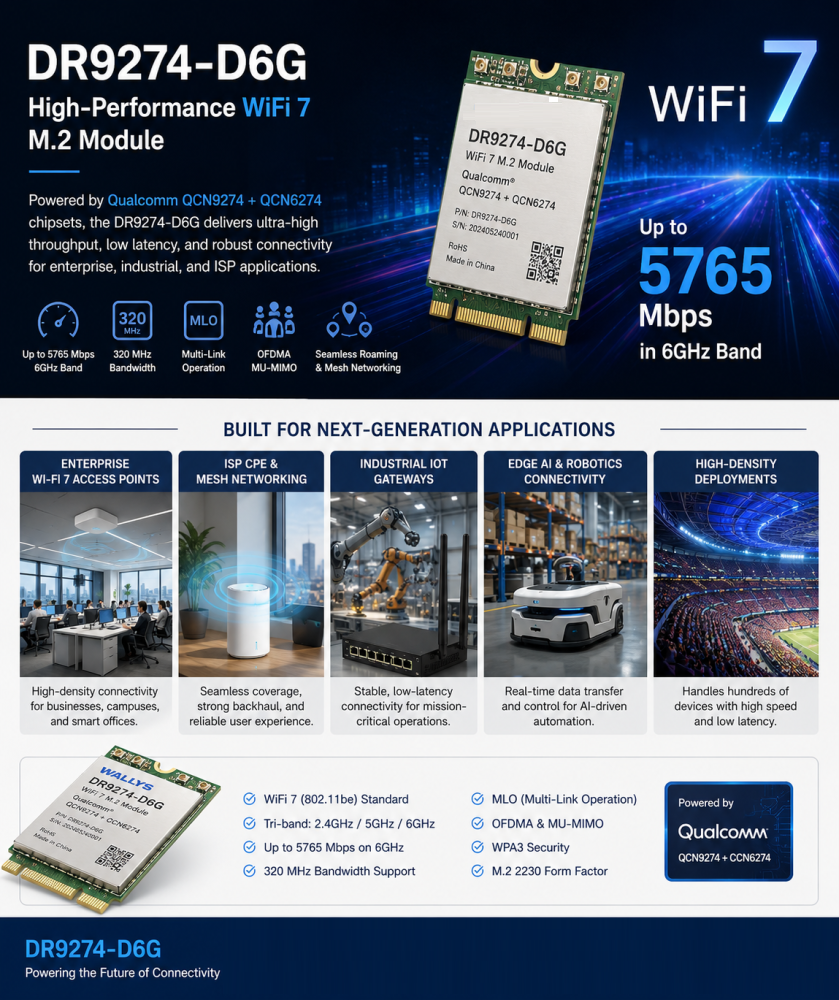
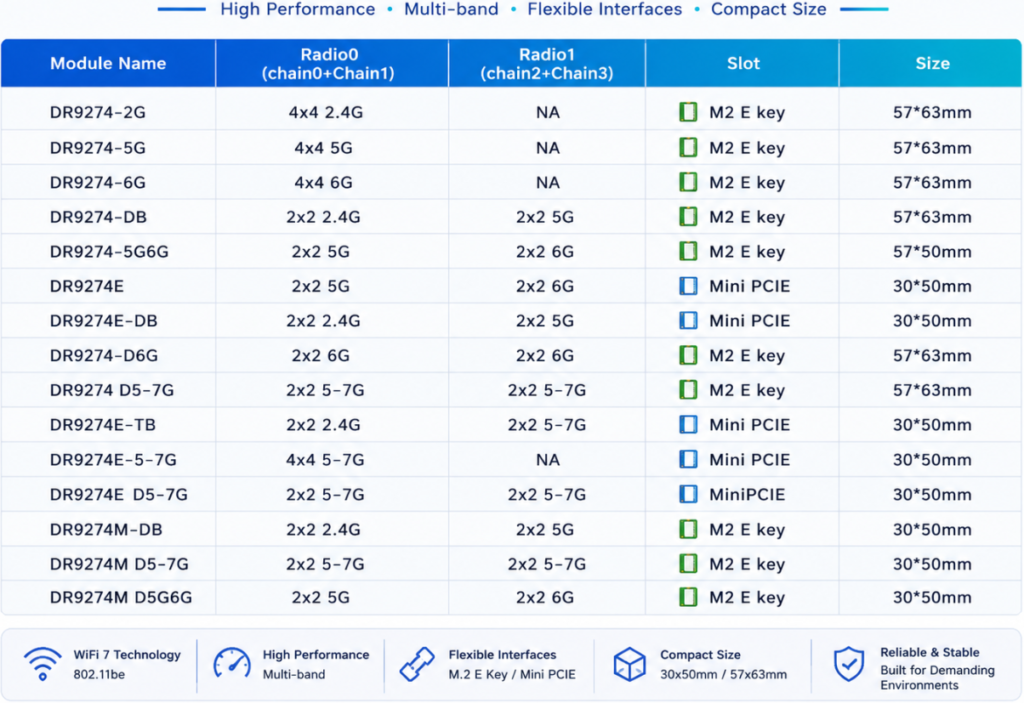
Airborne / terminal-side radio module. You want something small, power-efficient, and configurable — ideally a module where you can select or trim the band configuration (single-band 2.4GHz for a dedicated control radio, or dual-band where the payload allows) without carrying unused radio hardware and power draw. This is the role a WiFi 7 M.2 module built on a chipset like Qualcomm’s QCN9274/QCN6274 platform is designed for, with configurations spanning single-band, dual-band, and 4×4 single-band variants depending on what the airframe needs.
Ground-station aggregation board. This is where you want a flagship-class multi-band platform — four simultaneous bands, wide channels (up to 320MHz), high-order modulation (4096-QAM), multiple M.2 slots for additional radio cards, and dual 10GbE-class wired uplinks. This tier handles concurrent multi-aircraft connections, dynamic channel selection (AFC) to work around interference, and reliably backhauling the aggregated video streams to wherever they’re processed.
Edge gateway with onboard compute. For deployments where you want to do video processing or stream aggregation closer to the field — rather than pushing everything raw to the cloud — a tri-band gateway platform with high-speed wired I/O (dual 10GbE + multiple 2.5GbE) and an onboard AI accelerator tuned for networking workloads is the better fit. It handles wireless backhaul while also doing local compute, cutting the bandwidth pressure on the uplink.
A Practical Decision Order
When you’re actually speccing a system, work through it in this order:
Point-to-point or one-to-many? This determines whether OFDMA and fast roaming on the ground-station side are must-haves or nice-to-haves.
Does the control link need to be physically separated from the video link? This determines whether a single-band module or a multi-band board is the right call for each end of the system.
What are the payload’s power and space constraints? This determines module-level vs. board-level hardware on the airborne side.
Does the back end need edge compute or multi-stream video aggregation? If yes, prioritize a gateway platform with onboard AI acceleration and high-speed wired I/O.
FAQ
Is 2.4GHz or 5GHz better for a long-range drone control link? 2.4GHz generally holds up better over distance and around obstructions like terrain or crop canopy, which is why it’s the more common choice for the control link specifically. 5GHz and 6GHz are typically reserved for the video link, where the extra bandwidth matters more than raw range.
Do I need WiFi 7, or is WiFi 6 enough? It depends on whether you need MLO’s link redundancy and whether your video payload actually needs the extra bandwidth WiFi 7’s wider channels provide. Many long-range control links work fine on WiFi 6; WiFi 7 becomes more valuable as video resolution, aircraft count, or reliability requirements increase.
What’s the actual benefit of MLO for a drone link? Redundancy. The same data is sent across multiple links at once, so a momentary fade on one link doesn’t cost you the connection — it isn’t a way to assign different traffic types to different bands independently.
Should the airborne radio and the ground-station radio be the same hardware? No — they’re solving different problems. The airborne side prioritizes size, weight, and power; the ground station prioritizes aggregate throughput, multi-client handling, and wired backhaul capacity.
If you’re evaluating or redesigning the wireless subsystem in a drone flight-control or video-transmission stack — or migrating an existing deployment from WiFi 5/6 to WiFi 7 — reach out to info at 524wifi.com or .net. We build radio hardware across all three tiers described above and can walk through the specifics of your deployment.
Wireless is usually the last spec finalized on an edge AI hardware design and the first thing that becomes a bottleneck in the field. Worth a closer technical look before your next carrier board revision locks in.
The RF problem, precisely
Dual-band designs (2.4GHz + 5GHz) share spectrum with every consumer device, AP, and IoT sensor in range. In dense deployments — multi-robot fleets, factory floors, warehouses — this shows up as elevated retransmission rates, unpredictable jitter, and tail latency spikes under contention. For a control loop or a real-time inference pipeline streaming sensor data upstream, tail latency is what actually breaks the system, not average throughput.
WiFi 7 (802.11be) addresses this at the PHY/MAC level in three ways relevant to edge AI hardware:
6GHz band access — largely unlicensed spectrum with far lower device density than 2.4/5GHz today, meaning lower channel contention and more predictable airtime
320MHz channel bandwidth (vs. 160MHz max on WiFi 6) — higher raw throughput ceiling per link
Multi-Link Operation (MLO) — the ability to aggregate or fail over across bands simultaneously, so a device isn’t fully dependent on the health of a single channel
For an edge AI box pushing multi-camera streams, sensor fusion data, and periodic model/OTA updates concurrently, MLO plus 6GHz access is the difference between throughput that holds up under real RF load and throughput that only looks good on an open-air bench test.
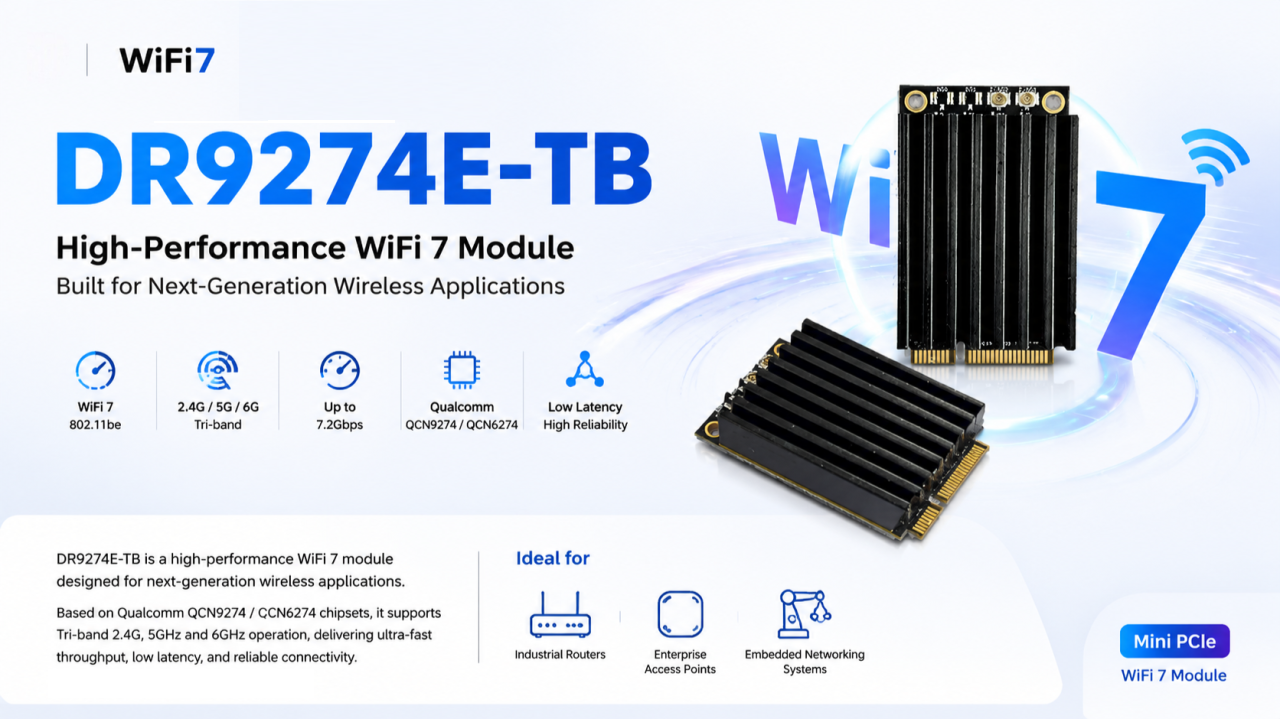
Module-level implementation: DR9274E-TB
We built the DR9274E-TB around this exact requirement — a Mini PCIe WiFi 7 module for teams integrating wireless into embedded and industrial platforms rather than designing RF from scratch.
Specs:
Chipset: Qualcomm QCN9274 (5G/6G radio) + QCN6274 (2.4GHz radio) — Qualcomm’s WiFi 7 platform, not a rebadged WiFi 6E part
Band support: Tri-band, 2.4GHz / 5GHz / 6GHz
Antenna config: 2×2 MIMO
Interface: Mini PCIe — integrates without a carrier board redesign on most existing embedded platforms
OS support: Linux-compatible — relevant if your stack runs on JetPack, Yocto, or a custom embedded distro
Build: Industrial-grade components rated for continuous operation, not consumer-grade parts pushed into an industrial enclosure
Where the tri-band architecture actually matters
Not every application needs 6GHz. It matters specifically where you have:
High device density (multi-robot fleets, dense AP deployments)
Environments where 2.4/5GHz spectrum is already saturated by other systems
That covers most edge AI computing platforms, industrial routers/IoT gateways, enterprise APs in high-density environments, outdoor CPE/wireless bridges, and mesh networking nodes.
The engineering takeaway
Specifying wireless the way you did for a WiFi 5/6 design — pick a dual-band module, move on — leaves latency and reliability headroom on the table that your compute stack has already outgrown. Tri-band WiFi 7 with MLO isn’t a marketing checkbox; it’s a direct answer to the contention and jitter problems that show up specifically under production RF conditions, not lab conditions.
Happy to go deeper on channel planning, MLO configuration, or driver-level integration for teams currently specifying wireless for a Jetson-based or other edge AI carrier board.
📩 Reach out to 524WiFi for datasheets, samples, or OEM customization.
A recent PtMP deployment we worked on had a familiar problem: the hardware checked every box on paper — right frequency band, right range, right radio — but once more than a handful of remote stations came online, performance got uneven. Some stations ran fine. Others lagged, dropped packets under load, or just underperformed relative to what the spec sheet promised.
The instinct in situations like this is usually to blame the radio hardware. In our experience, the actual bottleneck is almost always the scheduling layer — how airtime gets allocated across stations, not the raw RF performance.
What we found
Standard TDMA firmware implementations often use static or near-static slot allocation — every remote station gets a roughly equal time slice, regardless of what that station actually needs or how far it is from the base station. That works fine at low station counts. It breaks down as deployments scale, because distance, interference, and per-station data demand aren’t equal across a real network — a fixed schedule fights the physical reality it’s trying to serve.
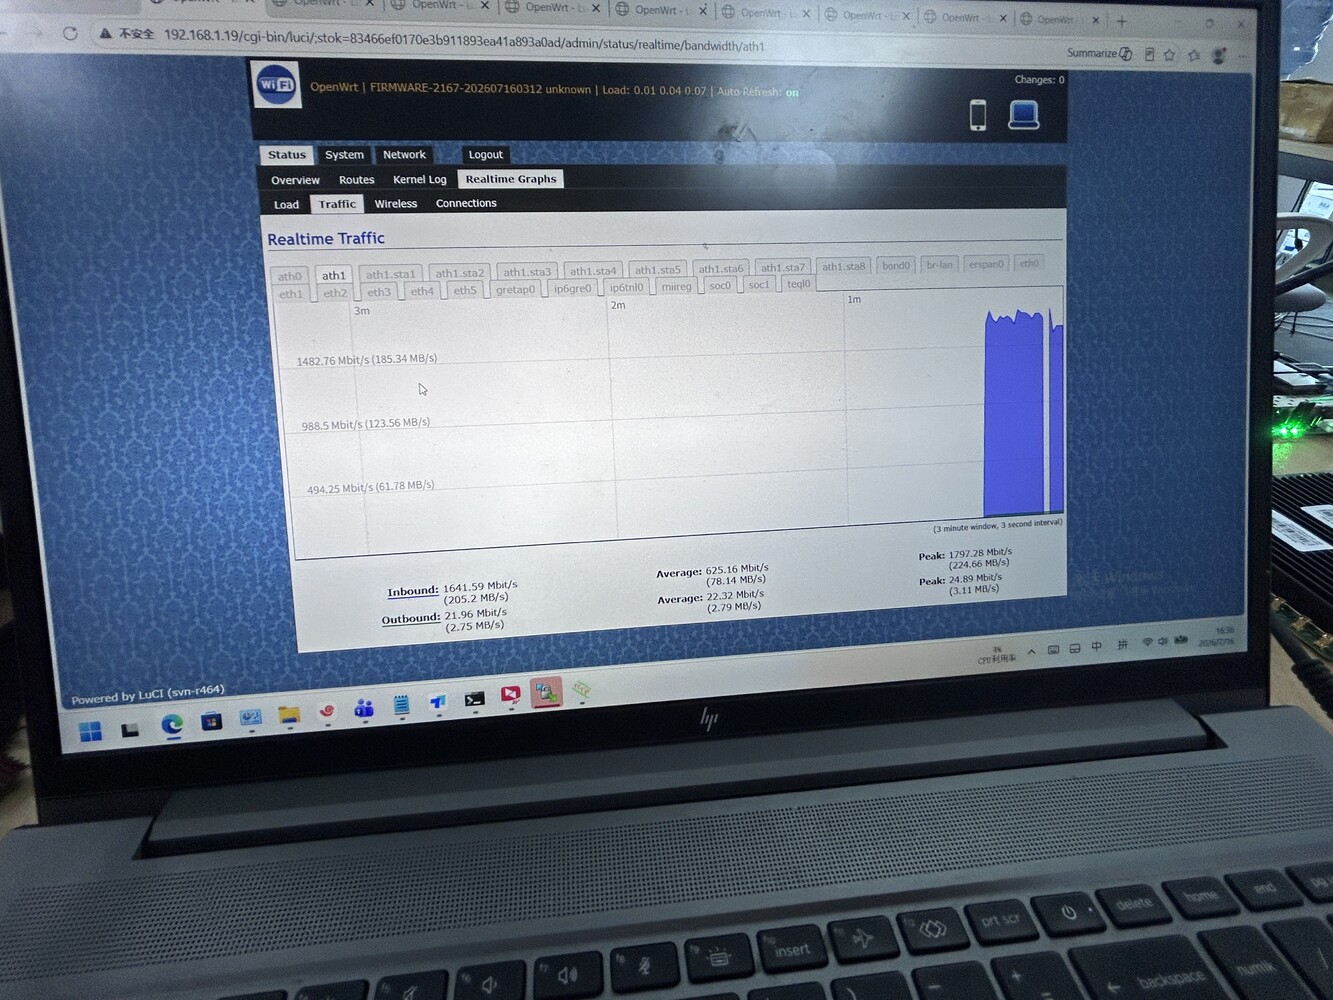
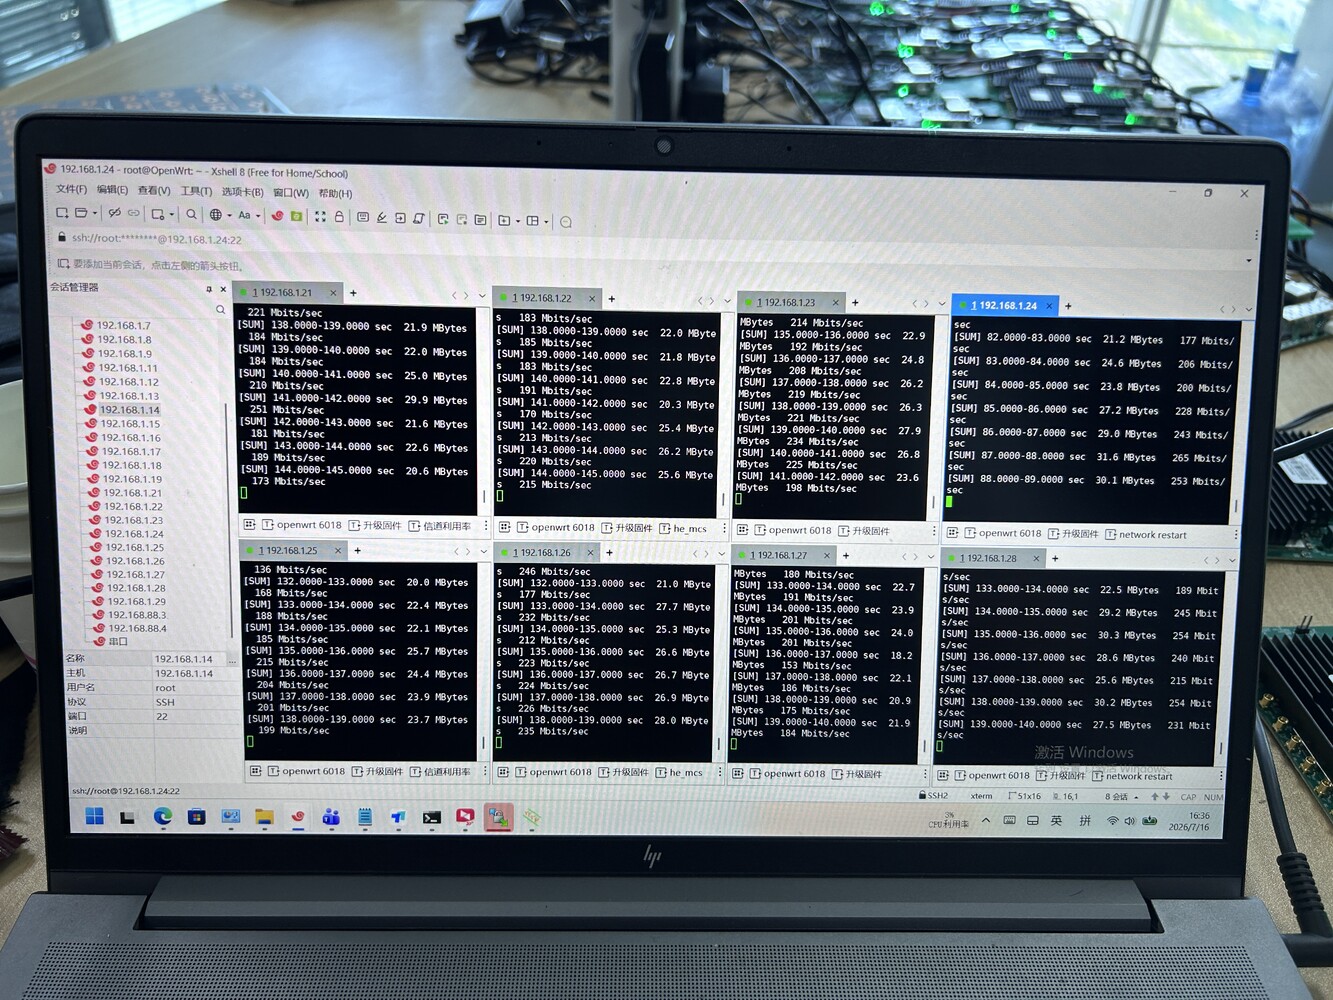
We rebuilt the scheduling logic on the firmware side to allocate airtime dynamically — closer to a priority/demand-weighted model than a fixed round-robin — and re-ran the same deployment topology: 8 remote stations, one base station, downlink test, same OpenWrt-based platform.
Result: per-station throughput of 130–265 Mbit/s, aggregate peak of 1,797.28 Mbit/s, aggregate average of 625.16 Mbit/s — with the spread between best- and worst-performing stations narrowing noticeably compared to the default static-scheduling baseline.
Why this matters beyond one deployment
The hardware didn’t change. The module, the antenna, the base station — none of it changed. What changed was the software layer managing how that hardware gets used across multiple simultaneous stations. That’s usually the part vendors don’t customize, because it means going deeper than swapping a chipset or bumping a spec sheet number.
This is also where we think there’s room for more collaboration than the industry typically does. A lot of teams building PtMP or multi-node wireless products — robotics, drones, distributed sensor networks — have strong hardware instincts but limited bandwidth to go deep on scheduling firmware, OpenWrt customization, or protocol-level tuning. That’s specifically the kind of work we do on the software side, independent of whether the hardware itself comes from us.
If your team has a multi-station deployment that’s hitting a similar wall — good radios, uneven real-world performance — we’re happy to compare notes, or scope what a scheduling-level fix would look like for your specific topology.
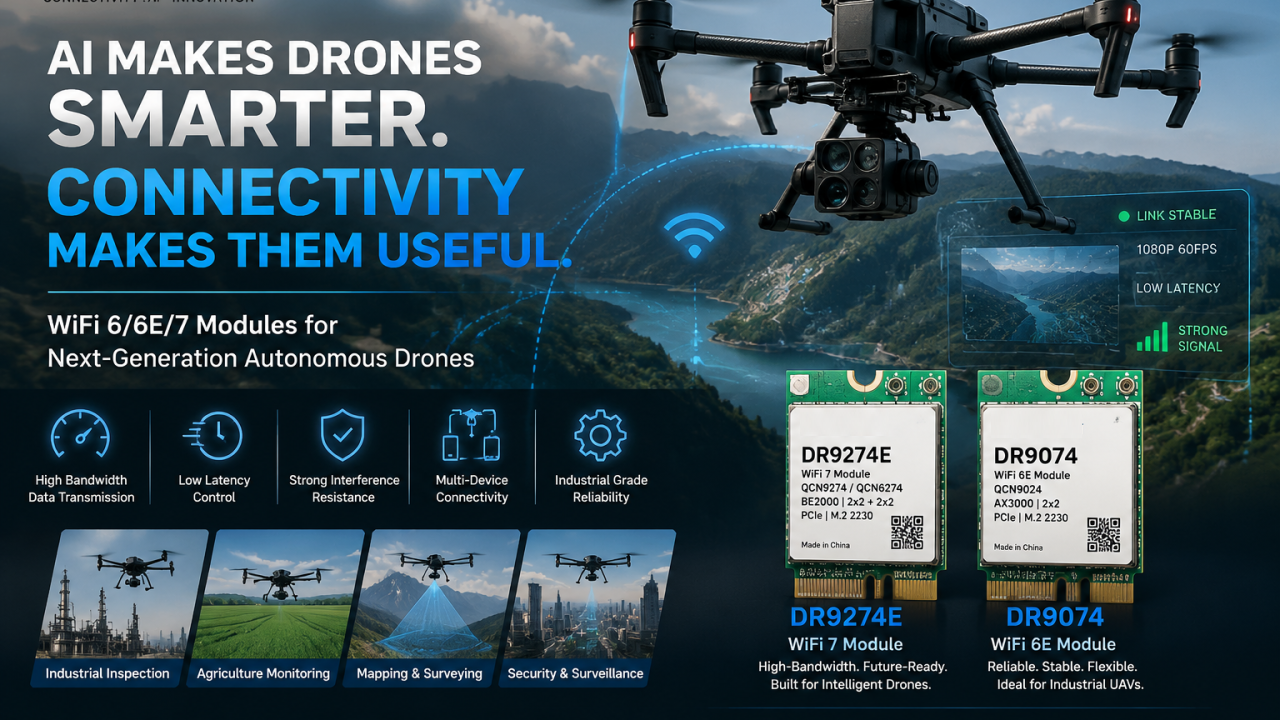
Powered by Qualcomm QCN9274 and QCN6274 platforms, the DR9274E WiFi 7 module is designed for applications requiring higher bandwidth, advanced connectivity, and future-ready wireless performance.
Potential applications include:
AI vision drones
Autonomous aerial robots
Industrial inspection UAVs
High-resolution video transmission systems
With WiFi 7 capabilities, it provides a powerful wireless foundation for intelligent devices requiring faster data exchange and more reliable connections.
DR9074 WiFi 6E Module: Reliable Connectivity for Industrial UAV Applications
Based on Qualcomm QCN9024, the DR9074 supports Tri-Band WiFi 6E operation across 2.4GHz, 5GHz, and 6GHz.
It is designed for applications requiring:
Stable wireless links
High-performance data transmission
Flexible frequency selection
Industrial deployment reliability
Suitable for:
Inspection drones
Mapping systems
Smart agriculture UAVs
Edge AI devices
Connecting the Future of Autonomous Flight
The future of drones will not only depend on better AI algorithms.
It will depend on the complete technology ecosystem:
AI provides intelligence. Sensors provide perception. Wireless connectivity enables action.
A smarter drone still needs a stronger wireless link.
At 524WiFi and Wallys, we are committed to providing Qualcomm-based WiFi 6 and WiFi 7 platforms for the next generation of drones, robotics, and edge AI applications.
The future of autonomous flight will not only be smarter.